
DivisonOfficer/Pixel-aligned_RGB-NIR_stereo_dataset
Pixel-aligned RGB-NIR Stereo Imaging and Dataset for Robot Vision CVPR 2025Jinnyeong Kim, Seung-Hwan BaekPOSTECH[arXiv] • [Code] • [Video] • [Dataset on HuggingFace] Overview This repository provides the code and dataset accompanying our CVPR 2025 paper: "Pixel-aligned RGB-NIR Stereo Imaging and Dataset for Robot Vision" We propose a novel robotic vision system equipped with two pixel-aligned RGB-NIR stereo cameras and a LiDAR sensor mounted on a mobile robot.… See the full description on the dataset page: https://huggingface.co/datasets/DivisonOfficer/Pixel-aligned_RGB-NIR_stereo_dataset.
Pixel-aligned RGB-NIR Stereo Imaging and Dataset for Robot Vision
CVPR 2025 Jinnyeong Kim, Seung-Hwan Baek POSTECH [[arXiv]](https://arxiv.org/abs/2411.18025) • [[Code]](https://github.com/your-repo-url) • [[Video]](https://your-video-link.com) • [[Dataset on HuggingFace]](https://huggingface.co/datasets/your-dataset-url)
Overview
This repository provides the code and dataset accompanying our CVPR 2025 paper:
"Pixel-aligned RGB-NIR Stereo Imaging and Dataset for Robot Vision"
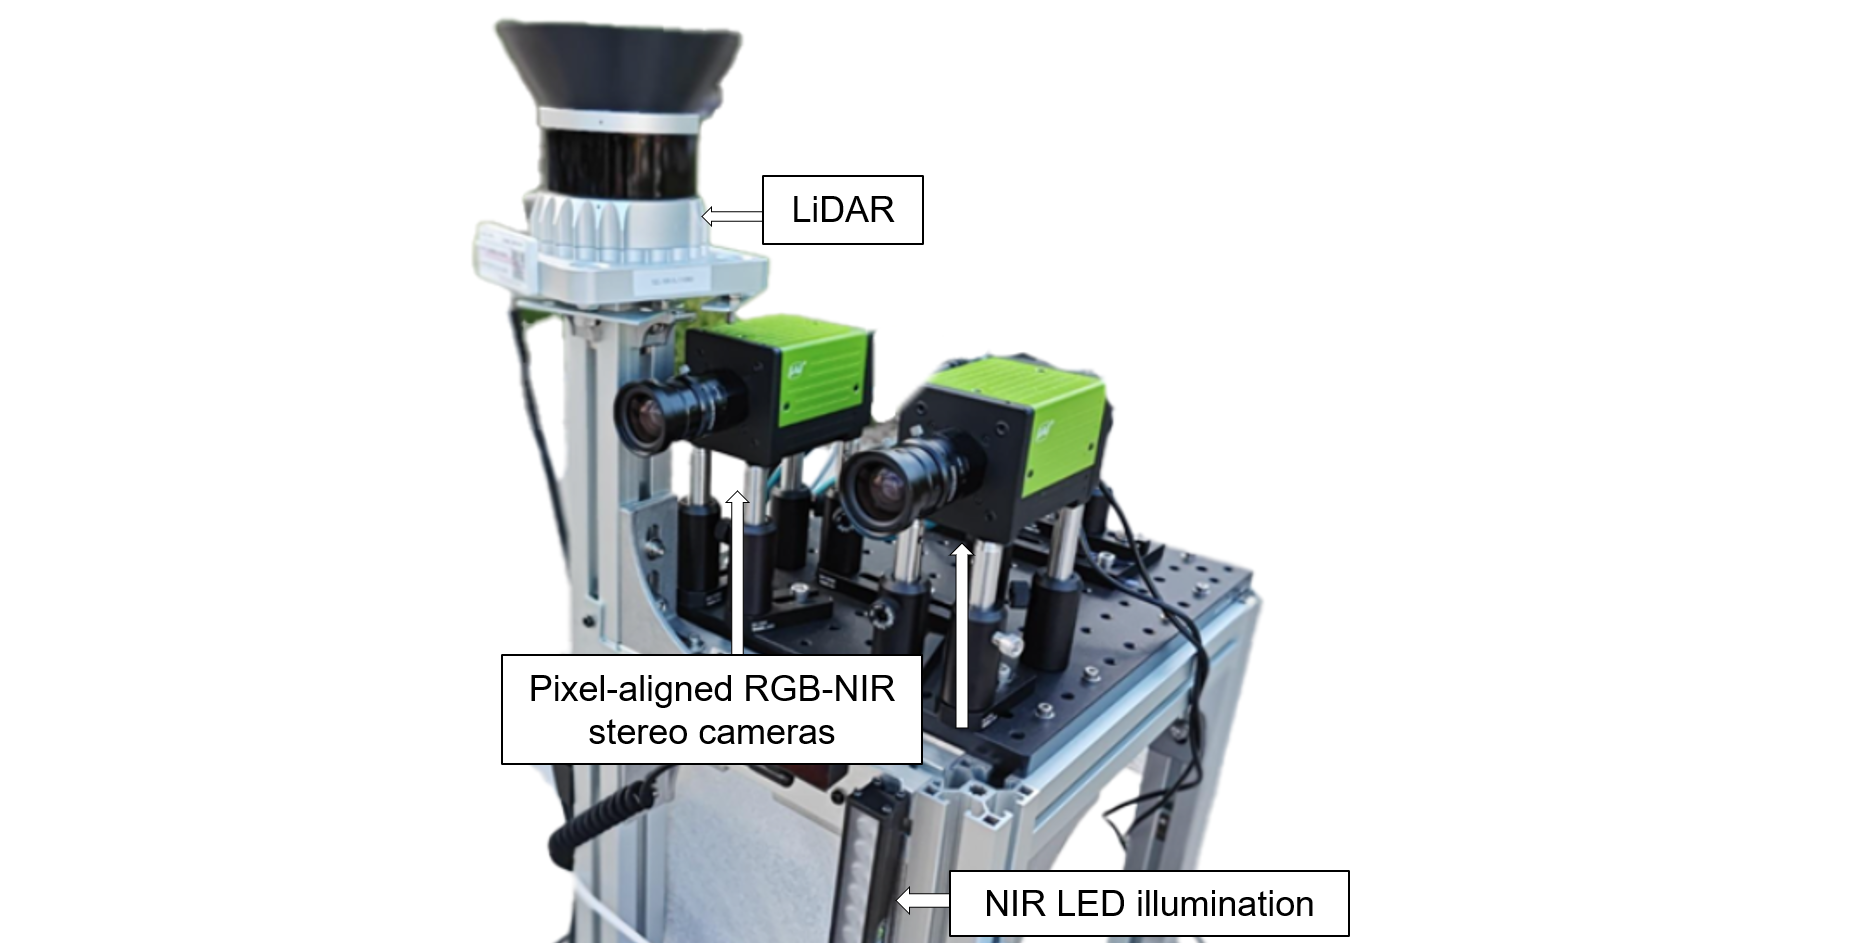
We propose a novel robotic vision system equipped with two pixel-aligned RGB-NIR stereo cameras and a LiDAR sensor mounted on a mobile robot. Our system captures RGB-NIR stereo video sequences and temporally synchronized LiDAR point clouds, offering a high-quality, aligned multi-spectral dataset under diverse lighting conditions.
✨ Highlights
- Pixel-aligned RGB-NIR stereo imaging for robust vision under challenging lighting.
- Continuous video sequences recorded using a mobile robot.
- Sparse LiDAR point clouds temporally synchronized with stereo imagery.
- Two proposed methods to utilize RGB-NIR pairs:
- RGB-NIR Image Fusion (pretrained model-compatible)
- RGB-NIR Feature Fusion (for fine-tuned stereo depth estimation)
📦 Dataset
We release a large-scale dataset for training and evaluating robot vision models in realistic environments.
📹 Data Statistics
📁 Per Frame Data Includes:
- Pixel-aligned RGB-NIR stereo images
- Sparse LiDAR point cloud (in camera coordinates)
- Sensor timestamps (synchronized)
🌗 Lighting Scenarios
<img width="920" alt="image" src="https://github.com/user-attachments/assets/a07bea4e-5674-4277-a585-f556ce9d4825" />
➡️ [Code is availabe on github](https://github.com/divisonofficer/Pixel_aligned_RGB_NIR_Stereo)
Each .tar.gz file follows below structure
frame1
--rgb
-----left_distorted.png (or left.png)
-----right_distorted.png (or right.png)
--nir
-----left_distorted.png (or left.png)
-----right_distorted.png (or right.png)
storage.hdf5
The frame ids are named after their creation date. _distorted.png image need to be undistorted. left.png and right.png are undistorted version.
storage.hdf5 is H5 database. it contains frame group with children of each frame ids.
📷 Imaging System
Our robotic platform integrates:
- Two RGB-NIR stereo cameras (pixel-aligned RGB and NIR sensors)
- LiDAR sensor
- Omnidirectional mobile base (360° movement)
- High-capacity battery (up to 6 hours)
- NIR LED bar light source for consistent active illumination
🔧 Methods
RGB-NIR synthetic data augmentation
See visualize/synth_aug_render.ipynb for method of synthetic data augmentation to build RGB-NIR training dataset.
RGB-NIR Image Fusion
We introduce an RGB-NIR image-level fusion technique for 3-channel vision tasks. This approach allows existing RGB-pretrained models to benefit from NIR information without additional fine-tuning.
Applicable to:
- Stereo Depth Estimation
- Semantic Segmentation
- Object Detection
See net/image_fusion.py for pytorch implementation.
RGB-NIR Feature Fusion (Stereo Depth)
We extend RAFT-Stereo with a novel feature-level fusion strategy, alternating between fused and NIR correlation volumes during iterative disparity estimation using GRUs.
See net/feature_fusion.py of implementation with RAFT-Stereo as baseline Our setup reflects the RGB with active illumination scenario:
- NIR provides robust depth cues
- RGB complements NIR with texture under normal lighting
📊 Experimental Results
Our experiments demonstrate that pixel-aligned RGB-NIR inputs:
- Improve stereo depth accuracy under low-light and high-contrast conditions
- Enable pretrained RGB models to generalize better
- Enhance robustness across lighting domains
📄 Citation
If you use this dataset or code, please cite our work:
@article{kim2025pixelnir,
  author    = {Jinnyeong Kim and Seung-Hwan Baek},
  title     = {Pixel-aligned RGB-NIR Stereo Imaging and Dataset for Robot Vision},
  conference = {The IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)},
  year      = {2025},
  doi       = {10.48550/arXiv.2411.18025},
  url       = {https://arxiv.org/abs/2411.18025},
}